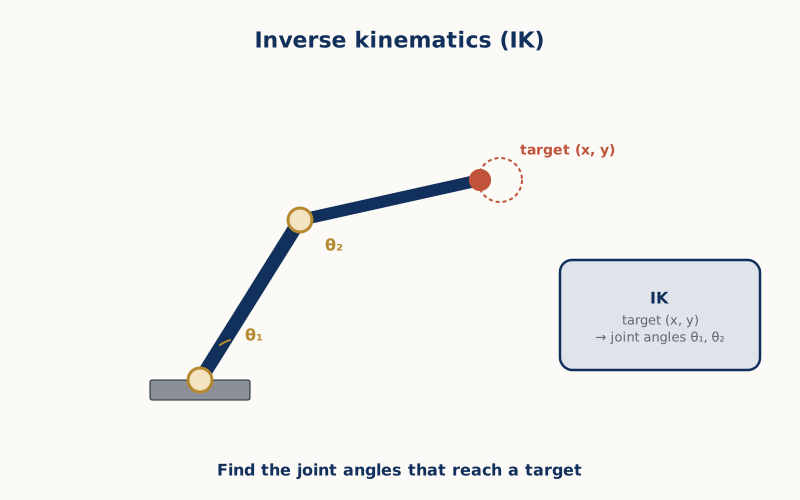
inverse kinematics (IK)
逆運動学
Definition 定義
The calculation of the joint angles of a robot or linkage that are needed to place its end-effector at a desired position and orientation.
Example 例文
Inverse kinematics was solved numerically to plan the motion of the robot arm.
日本語訳を表示
ロボットアームの動作を計画するために、逆運動学を数値的に解いた。
Collocations よく使う組み合わせ
- solve the ~
- ~ problem
- analytical ~
「~」の部分に inverse kinematics が入ります。